
Cone Beam Iterative Reconstruction#
examples/iterative_reconstruction.py reconstructs a 3D cone-beam phantom with
diffct.Projector. It runs on any supported trajectory, on one GPU, on several
GPUs in one process, or on several processes and nodes.
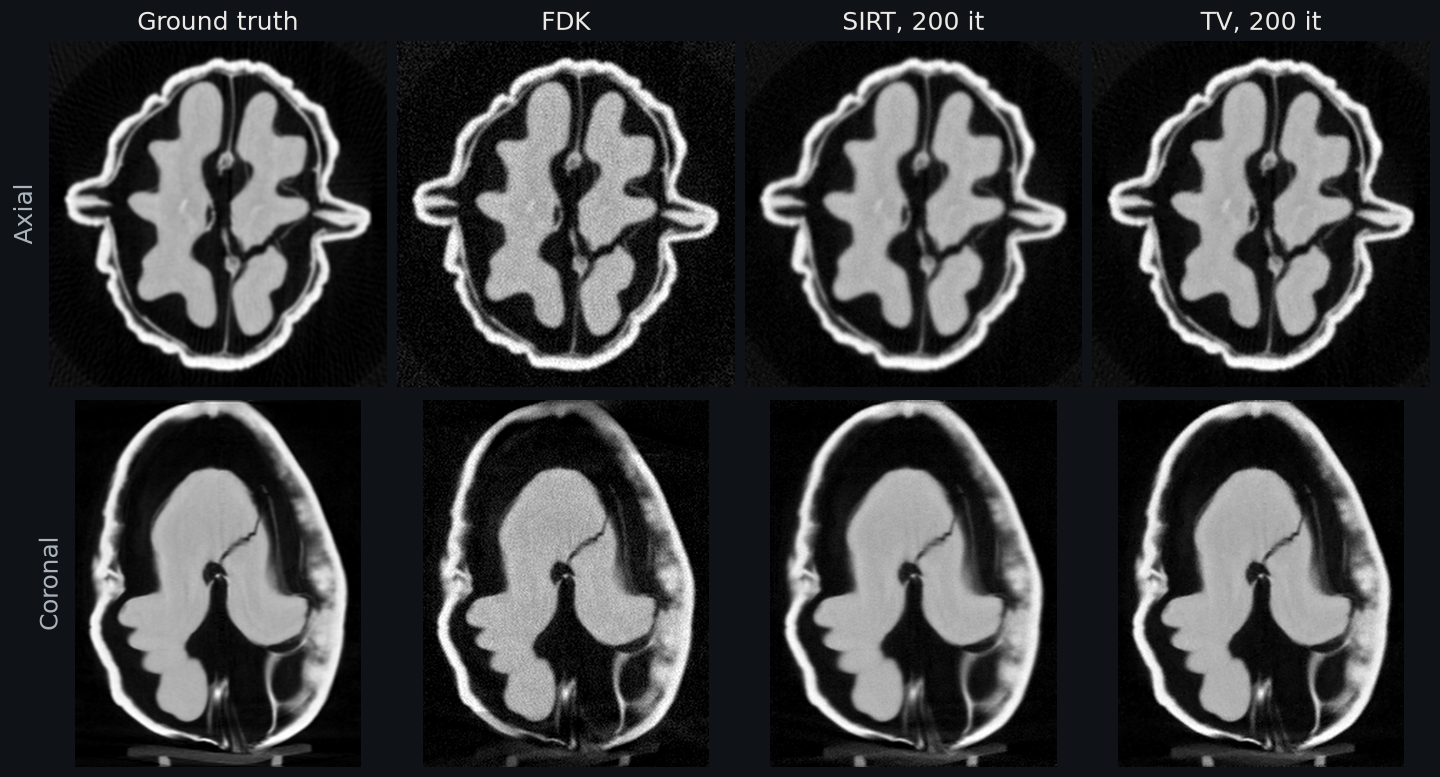
Simulated helical walnut scan from Measured Walnut: 720 views, 256³, 1% noise.#
Run it#
Run the commands from the root of a source checkout; pip install diffct does not
install the examples/ directory. See the “From source” tab in
Installation. --figure needs Matplotlib: pip install matplotlib.
python examples/iterative_reconstruction.py --trajectory helical
python examples/iterative_reconstruction.py --trajectory circular --devices 0 1 2 3
torchrun --nproc-per-node=4 examples/iterative_reconstruction.py
--devices and torchrun cannot be used together. For multiple nodes, see
Multiple GPUs and Nodes.
Options#
Option |
Meaning |
|---|---|
|
Volume edge length in voxels (default 128). |
|
Number of views (default 360). |
|
|
|
One or more of |
|
Override the per-algorithm defaults (CGLS 30, SIRT 200, TV 200). |
|
TV penalty weight for |
|
Gaussian noise, relative to the largest projection (default 0.0). |
|
|
|
Save central slices to this PNG. Requires Matplotlib. |
Pipeline#
Project the phantom with
Projector(cone beam, on the selected trajectory).Reconstruct with CGLS and SIRT. Both use the projector and its adjoint.
Reconstruct with TV-regularized nonnegative least squares. The script uses Adam and autograd for this solver.
When the full sinogram is on one GPU, compute an FDK baseline. On non-circular trajectories, FDK is a heuristic baseline, not an exact reconstruction.
Notes#
The iteration counts are demonstration settings, not a general convergence schedule. Choose a stopping rule for your data.
The TV weight is an example setting. Choose it for your geometry, resolution, voxel spacing and data scale. The solver uses half the mean squared residual per ray and a mean TV term. Its voxel differences are not divided by voxel spacing.
The script keeps complete input/output tensors on the process’s CUDA device. Native working buffers may stream; CGLS state can fall back to CPU.
To adapt the loss for several ranks, see Multiple GPUs and Nodes.
Source#
  1"""Iterative cone-beam reconstruction of a 3D phantom on any trajectory.
  2
  3Runs CGLS, SIRT and TV-regularized nonnegative least squares (Adam through
  4autograd), and FDK as a baseline when the full sinogram is on one GPU. The same
  5script runs on one GPU, on several GPUs in one process, or on several processes
  6and nodes:
  7
  8    python examples/iterative_reconstruction.py --trajectory helical
  9    python examples/iterative_reconstruction.py --devices 0 1 2 3
 10    torchrun --nproc-per-node=4 examples/iterative_reconstruction.py
 11    (multiple nodes: see examples/slurm/multi_node.sbatch)
 12
 13The phantom is the 3D Shepp-Logan by default. ``--phantom`` loads a ``(size,)*3``
 14volume with values in [0, 1] instead, for example the walnut volume written by
 15``walnut_reconstruction.py --save-volume``.
 16"""
 17
 18import argparse
 19import time
 20from pathlib import Path
 21
 22import numpy as np
 23import torch
 24
 25from diffct import Projector
 26from _common import (TRAJECTORIES, Scan, cgls, fdk, init_process, psnr, save_slices,
 27                     shepp_logan_3d, sirt, synchronize, tv_reconstruction)
 28
 29ALGORITHMS = {"cgls": cgls, "sirt": sirt, "tv": tv_reconstruction}
 30# CGLS converges fastest; SIRT and Adam need more, cheaper-to-tune steps.
 31DEFAULT_ITERATIONS = {"cgls": 30, "sirt": 200, "tv": 200}
 32
 33
 34def main():
 35    parser = argparse.ArgumentParser(description=__doc__, formatter_class=argparse.RawDescriptionHelpFormatter)
 36    parser.add_argument("--size", type=int, default=128, help="volume edge length in voxels")
 37    parser.add_argument("--views", type=int, default=360)
 38    parser.add_argument("--trajectory", choices=TRAJECTORIES, default="helical")
 39    parser.add_argument("--algorithms", nargs="+", choices=list(ALGORITHMS), default=list(ALGORITHMS))
 40    parser.add_argument("--iterations", type=int, help="override the per-algorithm default "
 41                        + str(DEFAULT_ITERATIONS))
 42    parser.add_argument("--devices", type=int, nargs="+", help="GPUs for one process (not with torchrun)")
 43    parser.add_argument("--tv-weight", type=float, default=1.0, help="TV penalty weight for the tv algorithm")
 44    parser.add_argument("--noise", type=float, default=0.0, help="Gaussian noise, relative to the largest projection")
 45    parser.add_argument("--figure", type=Path, help="save central slices to this PNG")
 46    parser.add_argument("--phantom", type=Path, help="(size,)*3 .npy volume in [0, 1] instead of Shepp-Logan")
 47    args = parser.parse_args()
 48
 49    distributed, device = init_process()
 50    if distributed and args.devices:
 51        parser.error("use either torchrun or --devices, not both")
 52    scan = Scan(args.size, args.views)
 53    trajectory = scan.trajectory(args.trajectory)
 54    # One Projector serves every mode: devices=... splits views over local GPUs,
 55    # distributed=True splits them over torchrun ranks.
 56    operator = Projector(trajectory, (args.size,) * 3, scan.detector, detector_spacing=scan.pitch,
 57                         devices=args.devices, distributed=distributed)
 58    rank0 = operator.rank == 0
 59    if args.phantom:
 60        volume = np.load(args.phantom).astype(np.float32)
 61        if volume.shape != (args.size,) * 3 or not (np.isfinite(volume).all() and 0 <= volume.min() and volume.max() <= 1):
 62            raise ValueError(f"{args.phantom} must hold a {args.size}^3 volume with values in [0, 1]")
 63        truth = torch.from_numpy(volume).to(device)
 64    else:
 65        truth = torch.from_numpy(shepp_logan_3d(args.size)).to(device)
 66    phantom_name = args.phantom.stem if args.phantom else "Shepp-Logan"
 67
 68    measurements = operator.project(truth)  # this rank's views
 69    if args.noise > 0:
 70        # Same noise for every launch mode: global peak, noise drawn for all views.
 71        peak = measurements.max()
 72        if distributed:
 73            torch.distributed.all_reduce(peak, op=torch.distributed.ReduceOp.MAX, group=operator.process_group)
 74        generator = torch.Generator(device=device).manual_seed(1234)
 75        noise = torch.randn((args.views, *scan.detector), generator=generator, device=device)
 76        measurements = measurements + args.noise * peak * noise[operator.view_slice]
 77
 78    if rank0:
 79        print(f"{args.trajectory} trajectory, {args.size}^3 volume, {args.views} views, "
 80              f"{operator.world_size} process(es), devices per process: {args.devices or [device.index]}")
 81    panels = [("phantom\nground truth", truth)]
 82    if not distributed:
 83        fdk(scan, measurements, trajectory)  # compile kernels and warm up
 84        synchronize(distributed)
 85        start = time.perf_counter()
 86        reconstruction = fdk(scan, measurements, trajectory)
 87        synchronize(distributed)
 88        print(f"  fdk   {1e3 * (time.perf_counter() - start):8.1f} ms            PSNR {psnr(reconstruction, truth):6.2f} dB")
 89        panels.append((f"FDK\n{psnr(reconstruction, truth):.1f} dB", reconstruction))
 90
 91    for name in args.algorithms:
 92        iterations = args.iterations or DEFAULT_ITERATIONS[name]
 93        options = {"weight": args.tv_weight} if name == "tv" else {}
 94        ALGORITHMS[name](operator, measurements, 1, **options)  # compile kernels and warm up
 95        synchronize(distributed)
 96        start = time.perf_counter()
 97        reconstruction = ALGORITHMS[name](operator, measurements, iterations, **options)
 98        synchronize(distributed)
 99        elapsed = time.perf_counter() - start
100        if rank0:
101            print(f"  {name:5s} {1e3 * elapsed:8.1f} ms ({1e3 * elapsed / iterations:6.2f} ms/it, {iterations} it)"
102                  f"  PSNR {psnr(reconstruction, truth):6.2f} dB")
103        label = (f"TV-regularized\nAdam, {iterations} it; {psnr(reconstruction, truth):.1f} dB"
104                 if name == "tv" else f"{name.upper()}, {iterations} it\n{psnr(reconstruction, truth):.1f} dB")
105        panels.append((label, reconstruction))
106
107    if rank0 and args.figure:
108        noise = f", {args.noise:.0%} noise" if args.noise > 0 else ""
109        save_slices(args.figure, panels, f"{args.trajectory} cone-beam scan, {args.size}³ {phantom_name}{noise}",
110                    vmax=1.0 if args.phantom else 0.4, sections=("axial", "coronal"))
111    if distributed:
112        torch.distributed.destroy_process_group()
113
114
115if __name__ == "__main__":
116    main()